Showing posts with label sci-tech. Show all posts

2 Dec 2011

Nextage humanoid robot (Robotics)

Nextage humanoid robot
Nextage, a humanoid robot that was developed by Kawada Industries, was specially designed so that it can function with the rest of humanity without looking out of place. Kawada Industries mentioned that it is “logical for robots that work together with people to be human-shaped” . This robot is able to function in a space that is equal to that of a person, where its arms have 12 degrees of freedom, and its back has one, where it can position itself to within 30 microns.

The robot’s head will also feature a stereo camera, where it is smart enough to recognize its surroundings as well as its own position, whereas hand cameras are able to recognize the kind of position of that the work it is doing in detail. So far, demonstrations have proved to be pretty impressive, where a trio of such robots actually function in perfect co-ordination as they would in the real world. Capable of picking up different parts, getting them together and tightening screws, these robots can work right away the moment you let them loose.
»»  read more

1 Dec 2011

Robotic Guards to Patrol South Korean Prison

Korean Robot Guard Prototypes of a prison guard robot are set to begin a test run in March, according to the South Korean news agency. Yonhap News Agency
The possibility of robot workers raises a certain type of futurey allure combined with a sense of danger — in a variety of settings, they could help humans work better and faster, but they could also replace us, or worse, maim us.

Robot guards are coming to a South Korean jail next spring, according to the Yonhap news agency. The guards are 5 feet tall and equipped with four wheels, a friendly face and who knows what sorts of pain rays and other implements. They are designed to look friendly to inmates, according to the designers.

The machines will monitor inmates for abnormal behavior. They'll be able to detect prisoner violence and even notice attempts at suicide, which researchers say will help reduce human guards’ workload. The robots will mostly work at night, patrolling correctional facilities and helping prisoners connect with officers, according to Yonhap. They come equipped with a “remote conversation function,” via the cameras mounted on their torsos.
Three prototype guard ‘bots will spend a month in a jail in the city of Pohang. The Asian Forum for Corrections, a South Korean research group, developed the robots in concert with Kyonggi University. The project will cost about $864,000.
»»  read more

25 Nov 2011

New Hydrogen Storage Material Based on Liquid Nitrogen developed

Hydrogen releases in the presence of iron chloride
In a research funded by the US Department of Energy, four scientists from the University of Oregon have developed a material to store hydrogen, using boron-nitrogen-based liquid-phase.This new material has displayed stability in both air and moisture. To be more specific, the research team developed a platform based on cyclic amine borane, which is also called BN-methylcyclopentane. Apart from being stable, the platform displayed the ability to retain hydrogen without changing phase. For the purpose of hydrogen desorption, the platform used iron chloride which enabled the conversion of the used fuel into the charged state.
This is a welcome change from the current storage materials which are solid, as liquid materials allow for a smooth transition from gasoline phase to hydrogen phase. During the course of the study, the researchers initially discovered six cyclic amine borane materials that were membered. On the release of hydrogen, these materials produced a large molecule. Although these materials were in their solid state, scientists altered the structure of the materials to convert them into liquid forms. The materials that were changed into liquid form in such a manner had low vapour pressure and retained their liquid form even upon the release of hydrogen.
Scientists believe that the new platform could be applicable in devices that use fuel cells. However, they also believe that the greatest hurdle in the commercial usage of such a platform would be the increase of hydrogen yield and the development of an effective mechanism to regenerate. The US Department of Energy is encouraging research to develop a solid or liquid hydrogen fuel carrier by 2017.
__________________________________________________________________________
»»  read more

23 Nov 2011

Robotics/Four-legged robot "guide dog" by Japan's NSK corporation

robodog by Japan's NSK corporation
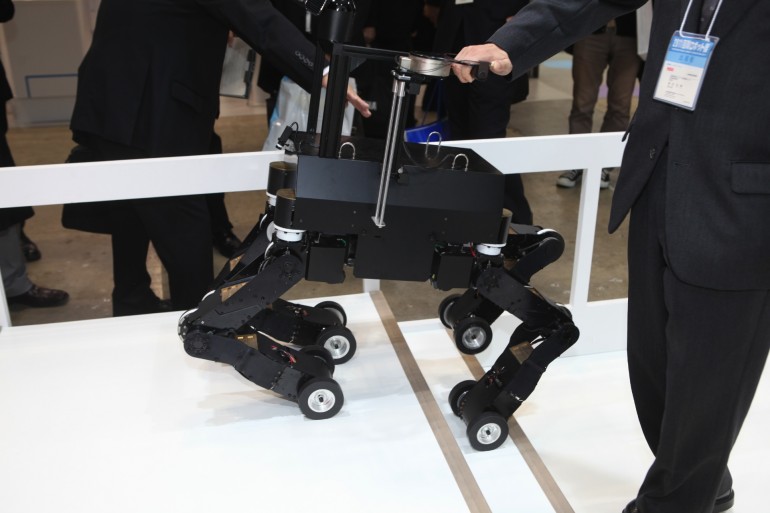
Guide dogs for the visually impaired provide an important service and help provide a welcome sense of autonomy to physically-challenged individuals. Unfortunately, the highly-skilled canines require about US$30,000 in training over several months, and always seem to be in short supply. The growing demand for these specialized animal companions gave a group of engineers from Japan's NSK corporation and the University of Electro-Communications just the impetus they needed to design a mechanical solution, and the robotic guide dog was born.
"Raising a guide dog takes a long time, and a dog can only work for about 10 years," said Katsuyuki Sagayama from NSK's Emerging Technology Research Center. So the number of guide dogs can't be increased instantly. Also, some people don't like having animals around. So we've developed this robot, as a way of doing similar things to a guide dog,"
The four-legged, eight-wheeled mechanical companion rolls on flat surfaces and can even tackle stairs. It employs attitude, shape and position data from an innovative hack of Microsoft's Kinect gaming device to sense stair number and width.
Sagayama pointed out that there are sensors on the legs, as well. "If we put a sensor on the head, the robot can see what's ahead, but it has blind spots around the legs. So the distance image sensor on the head is used to recognize steps overall, while information around the legs is obtained using proximity sensors."
To keep the user's grip solid and prevent the need to hunch over on stairs, the handle varies in height and angle. An intuitive force sensor on the end of the grip directs the robot's movement: push forward and it moves straight ahead, twist it and the robot turns. The "robodog" speaks with a computerized female voice, with which it conveys details about the surroundings, as well as instructions to the user on how to avoid obstacles. It will also eventually respond to voice commands, a function that will make it even more similar to the real dogs it's designed to replace.
While the rather noisy prototype is well thought-out, there are still many design and safety issues to be solved before a commercial version (still many years away) will be ready for market.
"We haven't considered the safety aspects very much yet," Sagayama said. "We've finally reached the level where the robot can recognize and climb stairs. So what we want to think about now is safety; for example, how to avoid falling, how to recover and keep climbing if a fall does happen, and how to prevent the user's fingers from getting caught when the robot moves."
Though there's no substitute for the love a dog can lavish on its owner, this device may eventually give many of those less fortunate than us a chance to safely be mobile and more independent. To us, that's several steps in the right direction.
GIZMAG
-------------------------------------------------------------------------------------------------------
»»  read more

22 Nov 2011

Bionic contact lens 'to project emails before eyes'

The vision is to stream real-time information in front of the eyes
A new generation of contact lenses that project images in front of the eyes is a step closer after successful animal trials, say scientists.
The technology could allow wearers to read floating texts and emails or augment their sight with computer-generated images, Terminator-syle.
Researchers at Washington University who are working on the device say early tests show it is safe and feasible.
But there are still wrinkles to iron out, like finding a good power source.
Currently, their crude prototype device can only work if it is within centimetres of the wireless battery.
And its microcircuitry is only enough for one light-emitting diode, reports the Journal of Micromechanics and Microengineering.
But now that initial safety tests in rabbits have gone well, with no obvious adverse effects, the researchers have renewed faith about the device's possibilities.
They envisage hundreds more pixels could be embedded in the flexible lens to produce complex holographic images.

For example, drivers could wear them to see journey directions or their vehicle's speed projected onto the windscreen.
Similarly, the lenses could take the virtual world of video gaming to a new level.
They could also provide up-to-date medical information like blood sugar levels by linking to biosensors in the wearer's body.
Delicate materials
Lead researcher Professor Babak Praviz said: "Our next goal is to incorporate some predetermined text in the contact lens."
He said his team had already overcome a major hurdle to this, which is getting the human eye to focus on an image generated on its surface.

Normally, we can only see objects clearly if they are held several centimetres away from the eye.
The scientists, working with colleagues at Aalto University in Finland, have now adapted the lenses to shorten the focal distance.
Building the end product was a challenge because materials used to make conventional contact lenses are delicate.
Manufacturing electrical circuits, however, involves inorganic materials, scorching temperatures and toxic chemicals. Researchers built the circuits from layers of metal only a few nanometres thick, about one thousandth the width of a human hair, and constructed light-emitting diodes measuring one third of a millimetre across
Dr Praviz and his team are not the only scientists working on this type of technology.
A Swiss company called Sensimed has already brought to market a smart contact lens that uses inbuilt computer technology to monitor pressure inside the eye to keep tabs on the eye condition glaucoma.
BBC News
------------------------------------------------------------------------------------------------
»»  read more

18 Nov 2011

World's 'lightest material' unveiled by US engineers


The metallic micro-lattice on a dandelion head Engineers say the material is less dense than aerogels and metallic foams
Engineers say the material is less dense than aerogels and metallic foams
A team of engineers claims to have created the world's lightest material.
The substance is made out of tiny hollow metallic tubes arranged into a micro-lattice - a criss-crossing diagonal pattern with small open spaces between the tubes.

The researchers say the material is 100 times lighter than Styrofoam and has "extraordinarily high energy absorption" properties.
Potential uses include next-generation batteries and shock absorbers.
The research was carried out at the University of California, Irvine and HRL Laboratories and is published in the latest edition of Science.
"The trick is to fabricate a lattice of interconnected hollow tubes with a wall thickness 1,000 times thinner than a human hair," said lead author Dr Tobias Schaedler.

The resulting material has a density of 0.9 milligrams per cubic centimetre.
By comparison the density of silica aerogels - the world's lightest solid materials - is only as low as 1.0mg per cubic cm. The metallic micro-lattices have the edge because they consist of 99.99% air and of 0.01% solids.

The engineers say the material's strength derives from the ordered nature of its lattice design.
By contrast, other ultralight substances, including aerogels and metallic foams, have random cellular structures. This means they are less stiff, strong, energy absorptive or conductive than the bulk of the raw materials that they are made out of.

William Carter, manager of architected materials at HRL, compared the new material to larger low-density structures.
"Modern buildings, exemplified by the Eiffel Tower or the Golden Gate Bridge are incredibly light and weight-efficient by virtue of their architecture," he said.
"We are revolutionising lightweight materials by bringing this concept to the nano and micro scales."
To study the strength of the metallic micro-lattices the team compressed them until they were half as thick.

After removing the load the substance recovered 98% of its original height and resumed its original shape.
The first time the stress test was carried out and repeated the material became less stiff and strong, but the team says that further compressions made very little difference.
"Materials actually get stronger as the dimensions are reduced to the nanoscale," said team member Lorenzo Valdevit.
"Combine this with the possibility of tailoring the architecture of the micro-lattice and you have a unique cellular material."
The engineers suggest practical uses for the substance include thermal insulation, battery electrodes and products that need to dampen sound, vibration and shock energy.
BBC NEWS
»»  read more

16 Nov 2011

Weird but helpful/This Robot stops people from snoring

Robot Jukusui-kun meaning “Deep Sleep.”
Snoring can be a real pain for couples, and in particular the person who isn’t snoring. There are a number of remedies to stop snoring including oral strips, mouth guards, special pillows, and those nose strips that are meant to help keep your airways open.
In Japan, they have come up with a much more advanced solution that takes the form of a robotic polar bear pillow.
This is definitely a case of “only in Japan,” but if it does stop someone snoring then I think many a husband or wife would welcome this bear into the bedroom with open arms.
The polar bear pillow is officially called Jukusui-kun, which translates to mean “Deep Sleep.” It is aimed at sleep apnea sufferers, and monitors the person sleeping with their head on its belly through a pulse-oxygen meter worn on their wrist, a conductive sheet underneath the bed sheets to remove the need for wires on or around the sleeper, and microphones located inside the bear.
The sleeper’s vital stats are fed into the system before sleep occurs. The microphone monitors the loudness of snoring, while the wrist monitor keeps an eye on oxygen in the blood. As that oxygen level falls the level of snoring increases, at which point the bear goes into action and tickles the sleeper’s face gently with its arm. The aim of this action is to get the person to turn and at least decrease or even stop the snoring, but at the same time doing so without waking them up.
The Deep Sleep system is the creation of Dr. Kabe from Wasaeda University in Japan. It was put on display at the International Robot Exhibition 2011 currently underway in Tokyo.
(VIA GIZMAG)
---------------------------------------------------------------------------------------------------------------------
»»  read more

15 Nov 2011

Miniature robot, pro rider?

Masahiko Yamaguchi's remote-controlled miniature robot
Riding a bike can be challenging enough for humans, so seeing inventor Masahiko Yamaguchi's remote-controlled miniature robot tooling along on an equally miniature bicycle is quite a thrill.
"I'm interested in artificial intelligence, and in that context, I think intelligence and skills have equal value," said Yamaguchi. "So my purpose in creating this robot was to pursue intelligence from the skills side. While I was thinking of suitable topics, my local science museum demonstrated a cycling robot. So I decided to consider cycling as the skill, and build a bicycle robot."
The pint-sized rider pedals with its own feet and maintains its balance by adjusting the handlebars as needed. To keep track of tilt and make corrections to prevent falling over, Yamaguchi made his own control board with a SH7125 CPU core and incorporated a Tamagawa Seiki TAG201 gyro into the design. A proportional-integral-derivative controller (PID) governs the robot's balancing action.
"PID control is a classical control method. It's used to calculate how far to turn the handlebars when the frame tilts. By calculating proportional, integral, and differential components for the tilt, and adding them, the system calculates how far to turn the handlebars when the frame tilts. Also, the robot needs to decide which direction to go in, so we use a remote control to instruct it," Yamaguchi explained.
Miniature robot waves onlookers
Because its mini-ride has no brakes (the little bicycle is fixed-gear), the operator can stop it simply by having the robot remove its feet from the pedals and put them on the ground.
"From now on, I'd like to link this robot's skill to its intelligence. I personally don't like using a remote control for the robot. I'd like to make the robot intelligent enough to ride by itself. This system is the first step toward doing that."
Source: Diginfo.tv
»»  read more

13 Nov 2011

Robot Suit for Nuclear Workers Unveiled

    The exoskeleton helps lighten the load of a 132-pound anti-radiation vest.
THE GIST
    * Workers are still dealing with the atomic emergency at Fukushima Daiichi plant in Japan.
    * A Japanese maker of exoskeleton robot suits has developed one that could assist nuclear workers.
In Tsukuba city, Ibaraki prefecture, a member of Cyberdyne wears the new Hybrid Assistive Limb (HAL) suit, which supports the 132 lb anti-radiation jacket. Cyberdyne
The Japanese maker of an exoskeleton robot suit to assist walking on Monday unveiled a model that could help nuclear workers weighed down by heavy anti-radiation vests in contaminated zones.
Cyberdyne, based northeast of Tokyo, demonstrated an upgraded version of the robot device called the Hybrid Assistive Limb, or HAL, that can be worn under anti-radiation tungsten vests as heavy as 132 pounds
Lightweight Tyvek protective outfits can provide a barrier between radioactive materials and the body, but are not effective in blocking radiation itself.
Vests made of tungsten can block radiation but are very heavy, making it difficult for workers to take on long shifts at highly contaminated sites, Cyberdyne noted.
"This new type of HAL robot suit supports the weight of tungsten-made protective clothing and enables their wearers to work on the site without feeling the burden," the company said in a statement.
"It is hoped that this will reduce risks of working under harsh environments and contribute to early restoration operations by humans in the wake of disasters," it said.
The massive earthquake and tsunami of March 11, 2011, sparked an atomic emergency at the Fukushima Daiichi plant operated by Tokyo Electric Power Co. (TEPCO) in the northeast of the country.
Efforts to contain the worst nuclear disaster since Chernobyl in 1986 are still continuing, with high levels of radiation hampering operations.
More than 2,000 employees of TEPCO and other companies are working at the plant on weekdays with the number falling on weekends, according to the plant operator.
It has not been decided whether the new robot suit will be used in work to contain the situation at the Fukushima plant.
HAL gives power to its wearer by anticipating and supporting the user's body movements using sensors monitoring electric signals sent from the brain to the muscles.
The company had already leased the lower-limb version of the battery-powered suit to 113 hospitals, welfare and other facilities by the end of October.
Via Discovery News
»»  read more

12 Nov 2011

Device that harvests water from thin air wins the James Dyson Award

Young Melbourne-based inventor Edward Linacre has won the 2011 James Dyson Award, making it the second year in a row where the prestigious prize has gone to an Aussie. Linacre stole this year's competition with his Airdrop irrigation concept that collects water from thin air. The Swinburne University of Technology design graduate was driven to transform an ancient cooling technique into a new sub-surface irrigation system, following the enduring Australian drought that saw high levels of farmer suicide along Australia's Murray- Darling Basin.
The Airdrop irrigation concept is a low-tech design that uses the simple process of condensation to harvest water from the air. Utilizing a turbine intake system, air is channeled underground through a network of piping that quickly cools the air to soil temperature. This process creates an environment of 100-percent humidity, from which water is then harvested. The collected water is stored in an underground tank, ready to be pumped out via sub-surface drip irrigation hosing. The Airdrop design also features an LCD screen displaying water levels, pressure strength, solar battery life and system health.
Although the backyard trial was successful on a small scale, Linacre did prove that it could be implemented on a large agricultural scale
The James Dyson Award is an international competition that attracts designs and inventions from young creators all over the world. As the winner, Linacre will receive GBP10,000 (US$14,000), with a further GBP10,000 (US$14,000) going to Swinburne's Faculty of Design.
»»  read more

10 Nov 2011

Robotics/Jumping spiderbot made using 3D printing technique

When it comes to deciding on a form of locomotion for their creations, roboticists have plenty of options to choose from. While many go for the tried and tested tank-like tracks or wheels, nature is also a veritable treasure trove of inspiration. That's just where Fraunhofer researchers have turned with a new eight-legged robot modeled on the same principle that moves spider legs. Not only does the design give the spiderbot the agility and stability of real spiders when getting around on the ground, it also features special joints that allow it to jump.
Like its biological brethren, the spiderbot is extremely stable, keeping four of its legs on the ground at any one time while the remaining four legs turn and ready themselves for the next step. Diagonally opposed members can also move simultaneously and bending the front pairs of legs pulls the spiderbot's body along, while stretching the rear legs pushes it.
As real spiders don't have extensor muscles at each of its leg joints, they rely on a sudden change in blood pressure in addition to the extensor muscles found on some joints to force the legs to extend rapidly and provide the full extension of the legs required for jumping. Borrowing this design, the researchers fitted the spiderbot's eight 20 cm (8 inch)-long legs and its body with pneumatically operated elastic drive bellows that bend and extend its legs with the force required to get it to jump.
The control unit, valves and compressor pump that provide the means of locomotion are located in the robot's body, which can also be fitted with various measuring devices and sensors, depending on the job at hand.
Instead of producing the robot using conventional mechanical-engineering technologies, the Fraunhofer team turned to a 3D printing process called selective laser sintering (SLS) that sees thin layers of a polyamide powder applied one at a time and melted into place using a laser. Not only does this process allow complex geometries and inner structures to be produced, but the resulting robot is also very lightweight and cheap to produce.
"We can use SLS to produce one or even several legs in a single operation; this minimizes assembly effort, saves materials and reduces the time it takes to build a robot. With the modular approach, individual parts can be quickly swapped as well. Our robot is so cheap to produce that it can be discarded after being used just once - like a disposable rubber glove," says Ralf Becker, a scientist at the Fraunhofer Institute for Manufacturing Engineering and Automation (IPA).
Although the spiderbot is still just a prototype, the researchers envision it could be used to explore environments that are hazardous or too difficult to access for humans, such as natural disaster areas and industrial or reactor accident sites. It could also be used to assist first responders and fire departments by broadcasting live images or tracking down hazards or leaking gas.
The Fraunhofer team will be displaying a prototype of the robot at the EuroMold 2011 trade fair that runs from November 29 to December 2 in Frankfurt.3
_______________________________________________________________________
»»  read more

Electronic nose aims to sniff out disease

Dr. Ranjan Nanda demonstrates the device at an experimental stage. The electronic nose aims to diagnose tuberculosis without a lab test.
A breathalyzer-like device that aims to detect tuberculosis, pneumonia and lung cancer from someone's breath could help replace time-consuming tests, researchers hope.
The electronic nose received a $950,000 grant from the federally funded Grand Challenges Canada and the Bill & Melinda Gates Foundation on Monday, to try to develop the hand-held device for use in the developing world.
"It's almost like a breathalyzer test that the police might use for alcohol," Dr. Peter Singer, CEO of Grand Challenges Canada, said in an interview from New Delhi.
"If they can bring that to the window of your car, what we're trying to do is bring the diagnosis of tuberculosis to the door of the hut in the village where it really needs to reach."
Scientists say electronic noses could also be created for early detection of lung cancer and pneumonia, also based on signature biomarkers of disease detectable in a patient's breath.
Singer called the device a "bold idea" with potentially a big payoff in preventing the 1.7 million deaths from TB each year, mainly in the developing world. Up to 400,000 of them could be saved with better diagnosis, he said.
People may not think about diagnosis as life-saving, Singer said. But if a patient in a village isn’t diagnosed, it is very likely many others will be infected and then die.
For the prototype, someone breathes into the device, which has a little tub at the end to capture the sample, which is then tested.
The battery-powered technology is based on the finding that people with TB have a different biological signature in their breath.
The two-year grant will be use to validate the finding in four centres throughout India.
Dr. Ranjan Nanda of the New Delhi-based International Centre for Genetic Engineering and Biotechnology, one of the lead researchers on the electronic nose project, aims to have a validated prototype by December 2013.
If it works, it could be in use shortly after that, Singer said.
The existng sputum test for TB has challenges, especially for developing countries that may not have facilities or trained lab staff, says Dr. Michael Gardam, an infectious disease specialist with Toronto's University Health Network.
"It's just such a wonderful idea and it's such a simple idea," Gardam said. "The challenge is going to be, at the end of the day, can it jump through all the necessary hoops to actually be something that people can use?"
The development of the device is a collaboration between Nanda's centre and and Next Dimension Technologies in California.
CBC News
»»  read more

8 Nov 2011

Honda shows smarter robot, helps in nuclear crisis

honda's human-shaped robot asimo
Honda's human-shaped robot can now run faster, balance itself on uneven surfaces, hop on one foot and pour a drink. Some of its technology may even be used to help out with clean-up operations at the stricken Fukushima nuclear plant.
Honda's demonstration of the revamped "Asimo" on Tuesday at its Tokyo suburban research facility was not only to prove that the bubble-headed childlike machine was more limber and a bit smarter.
It was a way to try to answer some critics that Asimo, first shown in 2000, had been of little practical use so far, proving to be nothing more than a glorified toy and cute showcase for the Honda Motor Co. brand.
Honda President Takanobu Ito told reporters some of Asimo's technology was used to develop a robotic arm in just six months with the intention of helping with the nuclear crisis in northeastern Japan.
The mechanical arm can open and close valves at Fukushima Dai-ichi nuclear power plant, which went into meltdown after the March tsunami, according to Honda. The automaker is working with the utility behind the problem plant, Tokyo Electric Power Co., to try to meet demands to bring the plant under control.
Ito acknowledged that the first idea was to send in Asimo to help out, but that was not possible because the robot cannot maneuver in rubble, and its delicate computer parts would malfunction in radiation.
But in Tuesday's demonstration, Asimo was able to walk without falling over 2 centimeter (0.8 inch) padded bumps on the floor.
asimo
It can also now jog faster than it did in 2005, at 9 kilometers per hour (5.6 mph), instead of the earlier 6 kph (3.7 mph), pushing better with its toes so its run was smoother and not as jerky.
Asimo was also able to distinguish the voices of three people spoken at once, using face recognition and analyzing sound, to figure out that one woman wanted hot coffee, another orange juice, and still another milk tea.
The new Asimo got improved hands as well, allowing individual movement of each finger, so it could do sign language.
"My name is Asimo," it said, making the signs of its words with stubby fingers.
It also opened a thermos bottle and gracefully poured juice into a paper cup.
Ito said Asimo had developed autonomous artificial intelligence so that it could potentially maneuver itself through crowds of people, without remote control or stopping each time to check on its programming.
But he acknowledged that making robotics into a practical business will take more time, meaning Asimo wasn't about to show up in any home soon.
"Maybe at the start this was a dream of engineers to make a machine that was close to a human being, like Astro Boy," he said. "We think Asimo is good."
Other manufacturers are also developing robots, eager to cash in on the expected needs of Japan's rapidly aging population.
Toyota Motor Corp., Japan's top automaker which makes the Prius hybrid and Lexus luxury models, is among those to have jumped on the robotics bandwagon.
In the past, it has shown robots that can play the violin and talk like receptionists. Last week, it showed a computerized device that latches on to the body to help old or sick people walk and keep balance.
Honda, which makes the Odyssey minivan and Accord sedan, has developed similar brace-like gadgets to help people get about.
Neither the Toyota nor Honda product is on sale yet.
Still, experts say such research is important to keep up.
"Maybe it can't be put to use right away, but it is definitely a technology that we should keep working on to advance," Hiroshi Kobayashi, a mechanical engineering professor at Tokyo University of Science, said of the new Asimo.
"It is common for what we achieve in research to turn out later to lead to many products," said Kobayashi, who has developed experimental robots.
STORY BY AP
»»  read more

1 Nov 2011

Robotics/Timeless Belt Climbing Platform-II wall climbing bot

The TBCP-II can transfer from horizontal to vertical surfaces over inside corners (as seen here) and outside corners
Wall-climbing, tank-like robot
Researchers have used a variety of technologies to give robots the ability to climb walls, such as magnets, rolling seals and electro-adhesive properties. But when it comes to wall-climbing robots its hard to go past the humble gecko for inspiration. The gecko's specialized toe pads containing hair-like structures that allow it to scale smooth vertical surfaces have already provided inspiration for the four-legged Stickybot and now researchers at Canada's Simon Fraser University Burnaby (SFU) claim to be the first to apply the gecko's wall-climbing technique to a robot that operates like a tank.
The researchers created adhesives that mimic the dry, but sticky toe pads of the gecko, also known as dry fibrillar adhesives, by using a material called polydimethylsiloxane (PDMS) that was manufactured to contain very small mushroom cap shapes that were 17 micrometers wide and 10 micrometers high.
"The thin, flexible overhang provided by the mushroom cap ensures that the area of contact between the robot and the surface is maximized," says Jeff Krahn. "The adhesive pads on geckos follow this same principle by utilizing a large number of fibers, each with a very small tip. The more fibers a gecko has in contact, the greater attachment force it has on a surface."
The researchers say applying the adhesive to tank-like robots driven by belts instead of legs offers several advantages. Tank-like robots have a simplified mechanical design and control architecture and also boast increased mobility and can be easily expanded if there is the need to increase the load a robot is carrying.
The 240 g (8.46 oz) robot developed by the SFU researchers, which has been given the catchy name of the Timeless Belt Climbing Platform (TBCP-II) has been fitted with a multitude of sensors that allow it to detect its surroundings and change its course accordingly. It is also able to transfer from a flat horizontal surface to a flat vertical surface over both inside and outside corners at speeds of up to 3.4 cm/s (1.34 in/s).
The SFU researchers say the wall-climbing technology employed in TBCP-II has wide-ranging potential applications, including inspecting pipes, buildings, aircraft and nuclear power plants, and in search and rescue operations.
The team's study A tailless timing belt climbing platform utilizing dry adhesives with mushroom caps was published today in the journal Smart Materials and Structures.
Source: GIZMAG
»»  read more

29 Oct 2011

Robotics/Olly: the web-connected robot that converts pings to odors

What if there were a way to add smells to the things you see every single day on the internet? To some, just the thought of that there scenario would induce nausea. To others -- primarily those who spend their days Googling various rose gardens around the globe -- it just might be the extra dimension to surfing that they've been waiting for. If you happen to find yourself tucked into that second camp, we'd like to introduce you to Olly, the web-connected robot that's capable of emitting smells based on inputs from the 'net. The critter was dreamed up by Tim Pryde and the folks surrounding the Don-8r (Foundry, if you're curious), and while there's currently no way to purchase one, instructions are forthcoming to produce your own with a 3D printer. In fact, it's recommended that users build a few, stack 'em up and connect different inputs (Twitter, Instagram, your mum's vegetarian cooking blog) to each one. It's the perfect cacophony... or the perfect disaster, depending on your browsing habits.
»»  read more

24 Oct 2011

Robotic Bug Gets Wings, Sheds Light On Evolution of Flight

Adding wings to a robotic bug improved running performance and stability. However, the boost may not have been good enough for flight. (Credit: Image by Kevin Peterson, UC Berkeley Biomimetic Millisystems Lab, All rights reserved.)
When engineers at the University of California, Berkeley, outfitted a six-legged robotic bug with wings in an effort to improve its mobility, they unexpectedly shed some light on the evolution of flight.
Even though the wings significantly improved the running performance of the 10-centimeter-long robot -- called DASH, short for Dynamic Autonomous Sprawled Hexapod -- they found that the extra boost would not have generated enough speed to launch the critter from the ground. The wing flapping also enhanced the aerial performance of the robot, consistent with the hypothesis that flight originated in gliding tree-dwellers.
The research team, led by Ron Fearing, professor of electrical engineering and head of the Biomimetic Millisystems Lab at UC Berkeley, reports its conclusions online on Oct. 18, in the peer-reviewed journal Bioinspiration and Biomimetics.
Using robot models could play a useful role in studying the origins of flight, particularly since fossil evidence is so limited, the researchers noted.
First unveiled by Fearing and graduate student Paul Birkmeyer in 2009, DASH is a lightweight, speedy robot made of inexpensive, off-the-shelf materials, including compliant fiber board with legs driven by a battery-powered motor. Its small size makes it a candidate for deployment in areas too cramped or dangerous for humans to enter, such as collapsed buildings.
A robot gets its wings
But compared with its biological inspiration, the cockroach, DASH had certain limitations as to where it could scamper. Remaining stable while going over obstacles is fairly tricky for small robots, so the researchers affixed DASH with lateral and tail wings borrowed from a store-bought toy to see if that would help.
"Our overall goal is to give our robots the same all-terrain capabilities that other animals have," said Fearing. "In the real world, there will be situations where flying is a better option than crawling, and other places where flying won't work, such as in confined or crowded spaces. We needed a hybrid running-and-flying robot."
The researchers ran tests on four different configurations of the robotic roach, now called DASH+Wings. The test robots included one with a tail only and another that just had the wing's frames, to determine how the wings impacted locomotion.
With its motorized flapping wings, DASH+Wings' running speed nearly doubled, going from from 0.68 meters per second with legs alone to 1.29 meters per second. The robot could also take on steeper hills, going from an incline angle of 5.6 degrees to 16.9 degrees.
"With wings, we saw improvements in performance almost immediately," said study lead author Kevin Peterson, a Ph.D. student in Fearing's lab. "Not only did the wings make the robot faster and better at steeper inclines, it could now keep itself upright when descending. The wingless version of DASH could survive falls from eight stories tall, but it would sometimes land upside down, and where it landed was partly guided by luck."
The flapping wings improved the lift-drag ratio, helping DASH+Wings land on its feet instead of just plummeting uncontrolled. Once it hit the ground, the robot was able to continue on its way. Wind tunnel experiments showed that it is aerodynamically capable of gliding at an angle up to 24.7 degrees.
Tree-dwellers vs. ground-runners
The engineering team's work caught the attention of animal flight expert Robert Dudley, a UC Berkeley professor of integrative biology, who noted that the most dominant theories on flight evolution have been primarily derived from scant fossil records and theoretical modeling.
He referenced previous computer models suggesting that ground-dwellers, given the right conditions, would need only to triple their running speed in order to build up enough thrust for takeoff. The fact that DASH+Wings could maximally muster a doubling of its running speed suggests that wings do not provide enough of a boost to launch an animal from the ground. This finding is consistent with the theory that flight arose from animals that glided downwards from some height.
"The fossil evidence we do have suggests that the precursors to early birds had long feathers on all four limbs, and a long tail similarly endowed with a lot of feathers, which would mechanically be more beneficial for tree-dwelling gliders than for runners on the ground," said Dudley.
Dudley said that the winged version of DASH is not a perfect model for proto-birds -- it has six legs instead of two, and its wings use a sheet of plastic rather than feathers -- and thus cannot provide a slam-dunk answer to the question of how flight evolved.
"What the experiments did do was to demonstrate the feasibility of using robot models to test hypotheses of flight origins," he said. "It's the proof of concept that we can actually learn something useful about biological performance through systematic testing of a physical model."
Among other robotic insects being tested in the Biomimetic Millisystems Lab is a winged, bipedal robot called BOLT (Bipedal Ornithopter for Locomotion Transitioning) that more closely resembles the size and aerodynamics of precursors to flying birds and insects.
"It's still notable that adding wings to DASH resulted in marked improvements in its ability to get around," said Fearing. "It shows that flapping wings may provide some advantages evolutionarily, even if it doesn't enable flight."
The National Science Foundation's Center of Integrated Nanomechanical Systems and the U.S. Army Research Laboratory helped support this research.
Credit: University of California - Berkeley.

»»  read more

22 Oct 2011

Robot 'Mermaids' Swim Seas to Detect Seismic Waves

Each robot is known as a Mobile Earthquake Recorder in Marine Areas by Independent Divers, or Mermaid. They are equipped with hydrophones, or underwater microphones, with which they record seismic waves from quakes and other earth-shaking phenomena as they ripple through the water. The mics can pick up the waves of quakes from as far away as 7,450 miles (12,000 km).
The seismic waves sent out by these temblors help scientists draw a picture of the Earth's insides.
"Seismologists use seismic waves very much as X-rays," said researcher Yann Hello, a geophysicist at the University of Nice Sophia Antipolis in Villefranche-sur-Mer, France.
For instance, seismic waves slow down when they hit hotter rock and speed up when they encounter  colder rock, and "we analyze this information and translate it into a picture of the hot and cold regions inside the Earth," Hello told OurAmazingPlanet.
The heat-driven motions of rock in the deep Earth underlie the movements of continents and the earthquakes that can devastate cities, so having a more detailed picture of what's happening beneath our feet could better prepare us for such natural disasters.
Ocean gaps
One problem facing the effort to "see" what's happening down below is the vastness of the Earth's oceans. There are very few seismic stations in the oceans, which cover nearly three-quarters of the Earth, leading to gaps in our picture of the world's interior. Having robots out there can thus help fill in our picture of the deep Earth, Hello said.
The Mermaids float freely about 3,300 to 6,500 feet (1 to 2 kilometers) below the ocean's surface. During the initial testing of the robots, currently under way, they surface after recording data for a short time so that researchers can gather their data.
In the future, the robots will surface only after detecting powerful seismic waves, transmitting their data to satellites before returning to their floating depth. Each robot carries a GPS unit to provide its location, as well as sensors for temperature, salinity and ocean current strength.
Two prototype Mermaids have just completed their longest autonomous trips so far. One had a carbon hull, the other, aluminum. The carbon hull is lighter, helping a robot carry more batteries and work for longer in the field, but the aluminum hull proved less sensitive to perturbations in the water and ballasting errors.
Achieving new depths
Launched in June in the Ligurian Sea just south of Nice, France, these prototypes were programmed to dive to a series of cruising depths, surfacing after each new depth was maintained for three or four days. They detected a strong earthquake 5,870 miles (9,450 km) away, a magnitude 7.4 temblor near the Fox Islands off the coast of Alaska. [Related: Seafloor Sensors Listen to Quake Rumblings]
The first fleet of a half-dozen fully operational aluminum-hulled Mermaids will be launched in the Indian Ocean in the second half of 2012. Their hardware will allow for oceanographic, weather, biological and seismological observations, researchers said.
The technology of these robots will only improve over time, researchers added. Scientists and engineers are now refining the artificial intelligence algorithms that help the Mermaids decide what seismic waves are meaningful or not, and are hoping to develop larger and more lightweight floats with batteries that allow them to survive for up to five years.
The scientists detailed their findings in the Oct. 4 issue of the journal Eos.
»»  read more

‘Son of Osprey’ to Replace All Army Copters

The V-22 Osprey tiltrotor flown by the Marines and Air Force crashes or burns much more often than the military cares to admit. But that hasn’t stopped Osprey-maker Boeing from pitching a new tiltrotor for an ambitious Army program aimed at replacing almost everything the ground combat branch flies … with a single aircraft design.
That’s potentially thousands of new tiltrotors, which take off vertically like helicopters but fly fast like airplanes, thanks to their rotating engine nacelles — but which are also vulnerable to dangerous aerodynamic phenomena and, in the V-22’s case, have been plagued by engine problems.
By continuing to invest in the V-22, the Pentagon is doubling down on a risky bet. If Boeing’s “son of Osprey” gets the greenlight for the comprehensive Joint Multi-Role program, the military will be going all in. But a lot could change between now and 2025, when the first of the new rotorcraft is (loosely) scheduled to enter service. And there’s reason to believe a new tiltrotor could avoid the pitfalls of the Osprey’s design.
Boeing showed off some preliminary artwork of their Joint Multi-Role tiltrotor at an Army confab in Washington, D.C., last week. The art shows a small, sleek scout version and a larger cargo model. “Those images are nothing more than artist concepts and not necessarily associated with a specific design philosophy,” Boeing spokesman Chris Haddox told Danger Room. “The work is just getting underway.”
All the same, the Boeing concept shows apparent improvements over the V-22. Specifically, simpler wings and better rotors.
To fit aboard the Navy assault ships that carry Marines into battle, the V-22 had to have a wing that could fold back along the fuselage — at the cost of extra weight and complexity. The Osprey’s rotors also had to be smaller than ideal for a 25-ton aircraft, forcing the engines to work harder and run hotter.
Over the years, engineers have proposed solutions to this problem. Farhan Gandhi, an engineer at Penn State University, proposed a telescoping rotor blade that would automatically increase in length during a tiltrotor’s helicopter mode, increasing its lifting ability. One retired V-22 engineer told analyst Lee Gaillard that replacing the V-22’s three-blade rotor with a new, five-blade model (.pdf) would boost performance. In the end, Boeing opted for tweaks to the V-22’s software to squeeze every last bit of performance out of the existing design.
Boeing’s conceptual future tiltrotor seems to avoid these half-measures by incorporating bigger rotors from the outset on the scout model, and twin rotors — that is, two sets of blades on each nacelle — for the cargo version. An Army tiltrotor could probably also skip the folding wing mechanism, as seems to be the case in the artist’s renderings. The result could be a safer, better-performing tiltrotor than the troubled V-22.
Photo credit: US Air Force
»»  read more

20 Oct 2011

Robotics/The $400,000 Poop-Scooping Robot

Image: GRASP Lab
We've all seen them, casually standing there, fiddling with their phone or gazing at the clouds, as if their dog isn't dropping a deuce right there on the sidewalk. I'm talking about the people who can't be bothered to clean up after Fido has done his business. Sure, no one likes picking up dog turds with a plastic bag, but I don't particularly like hop-scotching around Dachshund droppings while on my evening promenade.
Thanks to some researchers over at the University of Pennsylvania's GRASP Lab, both culprits and victims of curbside canine malfeasance should have reason to rejoice.
Say hello to the Perception Of Offensive Products and Sensorizied Control Of Object Pickup, also known as POOP SCOOP. It's a robot designed by the GRASP Lab researchers that is capable of finding and removing 95 percent of pooch's poo at a sidewalk-sparkling rate of one ppm (that's poo per minute).
The robot uses color cameras to scan for Potentially Offensive Objects for Pickup of the high fiber variety. When they're identified, the robot uses a standard store-bought pooper scooper to gobble-up the piles and place them in a bucket. If POOP SCOOP's aim is off, it will try again.
For now, the robot exists as a clunky, tongue-and-cheek project, but the technology is nothing to scrape your shoe about. What is, however, is the robot's $400,000 price tag. With plastic bags freely available after each bodega run, or this more affordable biodegradable option, I suspect the robot won't be catching on anytime soon, especially when it costs as much as a Lamborghini.
Perhaps with a few modifications and price reduction, we could see the POOP SCOOP patrolling sidewalks everywhere. Until then, please pick after your dog...or watch your step.
[Via Inhabitat]
»»  read more

Robotics/Bug-Like Robotic Drones

Big Eyes, Tiny Hairs (credit: JJ Harrison via Wikimedia)
Micro air vehicles, or MAVs, make for a tantalizing option for intelligence and surveillance agencies looking to surreptitiously gather information or deliver surveillance devices without being seen. But MAVs--usually modeled after small birds or insects-- are notoriously unstable in flight and difficult to maneuver in cluttered environments. So the Pentagon is handing out research contracts to make the DoD’s little robotic bugs more stable by making them more bug-like. Specifically, the DoD wants big bulging bug eyes and hairy wings for its MAVs.
The main problem with MAVs has to do with the way they respond (or don’t respond) to dynamic environments--things like shifting or gusting winds, moving bodies, and other variables that have to be accounted for in realtime. MAVs are tiny, so there’s not a lot of space for computing assets or sensor payloads, and that leads to a sort of intractable problem: how can engineers make these things smaller and more capable while also adding increased situational awareness and better in-flight processing?
When facing a tough problem like this a little biomimicry never hurts, and that’s exactly where the Pentagon is looking with its recent contracts. If two research stipends recently handed down are any indication, the micro-drones of the future may have tiny hair-like sensors all over their bodies and big, compound eyes.
The cilia-like hairs will serve to keep the drones’ hovering and flight stable by sensing changes in air flow at the tiniest levels. That means the drone could sense a wind gust coming shortly before it arrives, allowing it to compensate for the change in circumstance. It would also aid in maintaining overall stability during flight, as the MAVs central processor would possess a constant awareness of--and the ability to manipulate--the boundary flow layer of air surrounding the drone as it hovers and flies.
The bug-like compound eyes would similarly help MAVs navigate in cluttered spaces by increasing the amount of visual data available to the drones’ processors. An on-board minicomputer would process images in realtime, using those visual cues to automatically avoid obstacles and navigate cleanly and efficiently.
[credit:Danger Room]
»»  read more
Related Posts .